“Catch-up” motion stage can be seen when the tote returning to the structure moves faster to latch other totes before leaving the carrier.
The cantilevered structure such that the carrier can go under the tote, v. reach in and grab, was another one of my contributions that can be clearly seen here.
Gimbal for Off-road Autonomy
(SaberCat)
Public domain Image Source: https://www.linkedin.com/feed/update/urn:li:activity:7281459034287693824/
My Contributions
Gimbal system developed over a 4-month time frame culminating in 8x systems deployed during a 4-week test event with end-users
In under 1 month made and tested a preliminary prototype for validating motor and controller performance, completing the system tuning and programming for this initial effort individually
Implemented CAN DAQ system to facilitate testing/data capture without need for software resources
Warehouse Automation
(Free Space Robotics)
Overview: https://www.freespacerobotics.com/
My Contributions
Key conceptual contributions in the areas of tote motion timing, identifying need for “catch-up” motion stage, and carrier, tote, & structure system designs
Completed design and proof of concept build of tote and structure systems conducting testing on the system to validate performance, successfully demonstrating feasibility to the customer
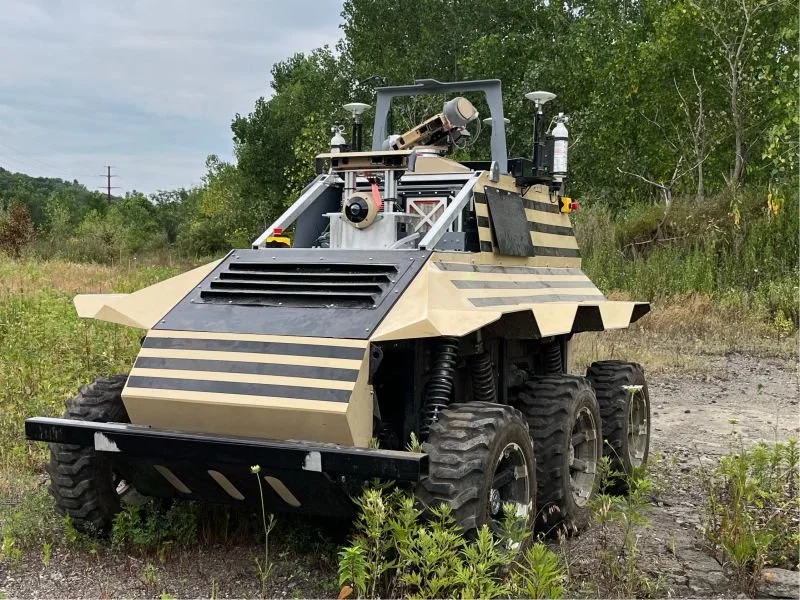
This image is not of a final build but the gimbal on the top is a good representation of what the 8x deployed systems looked like though.
The bottom camera module is on a temporary 80/20 frame here to work with the navigation software implementation that existed at this point in the project.